Overview
Any direction, no turning
An Android app
Hold the stick to drive, let go to stop. A second stick slides her sideways.
Follow, hello, dance
She keeps your hand 30 cm from her front sonar, and wiggles or spins on the spot, with her wall stop still on.
Omnidirectional
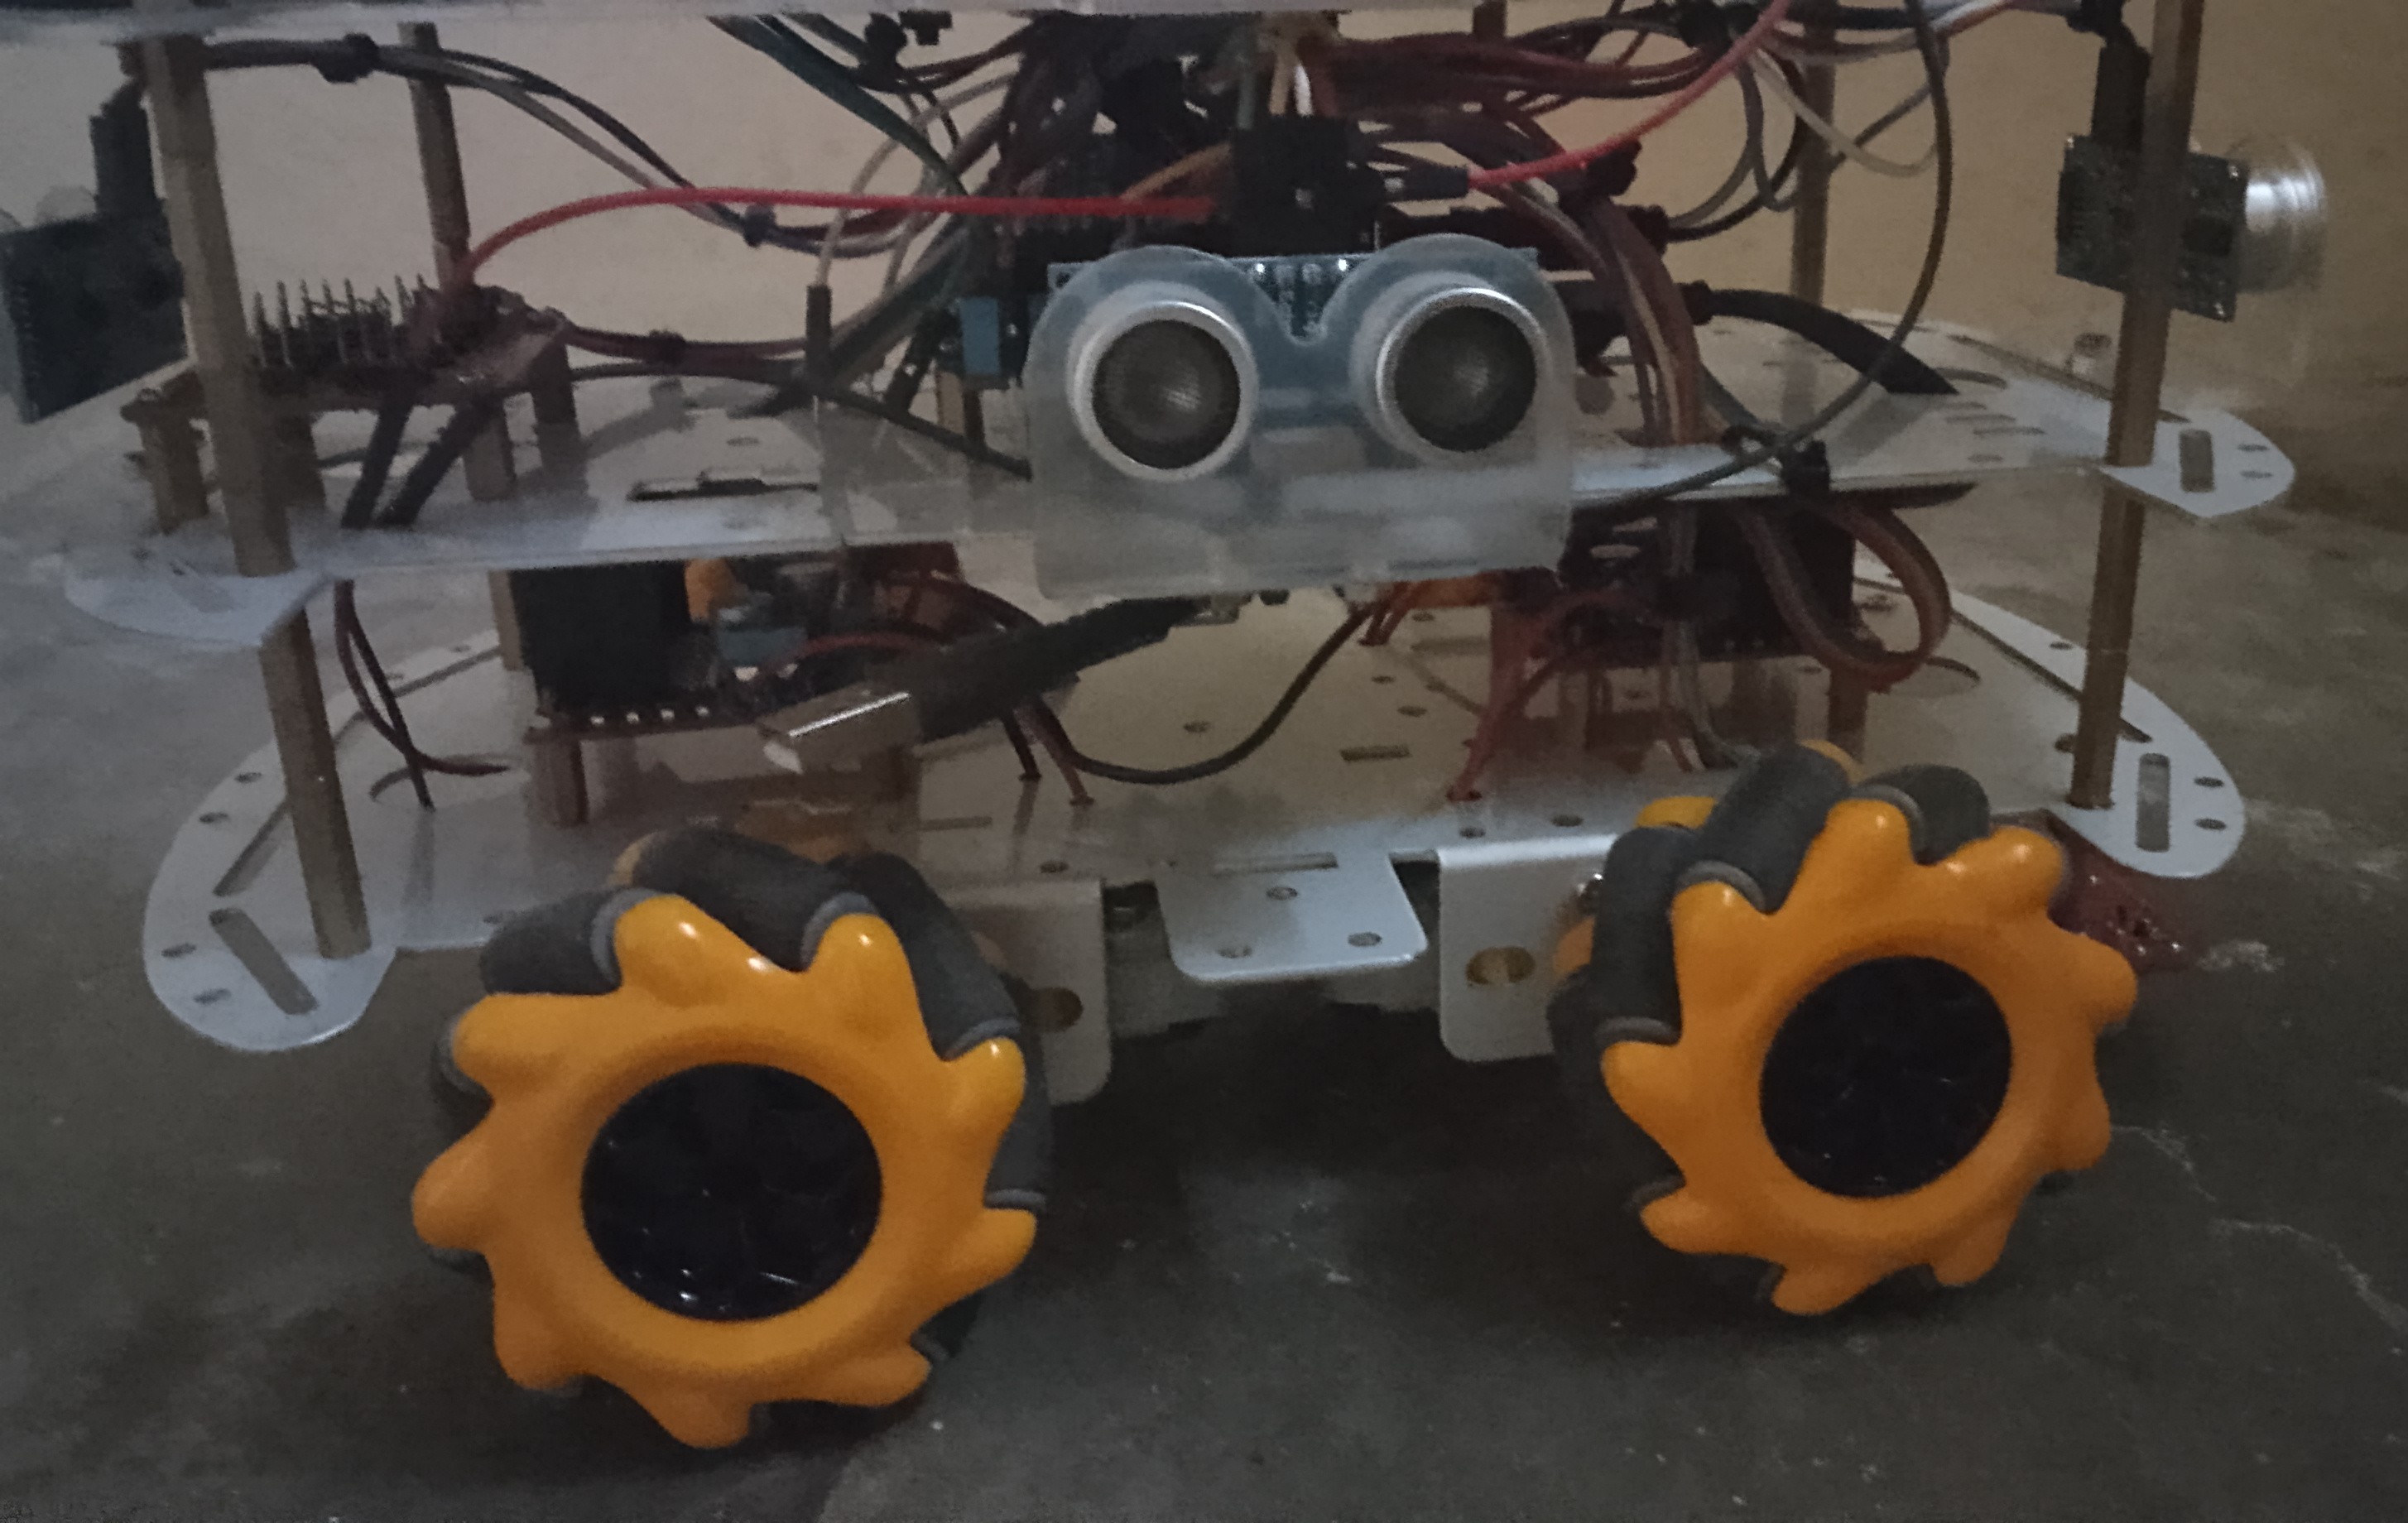
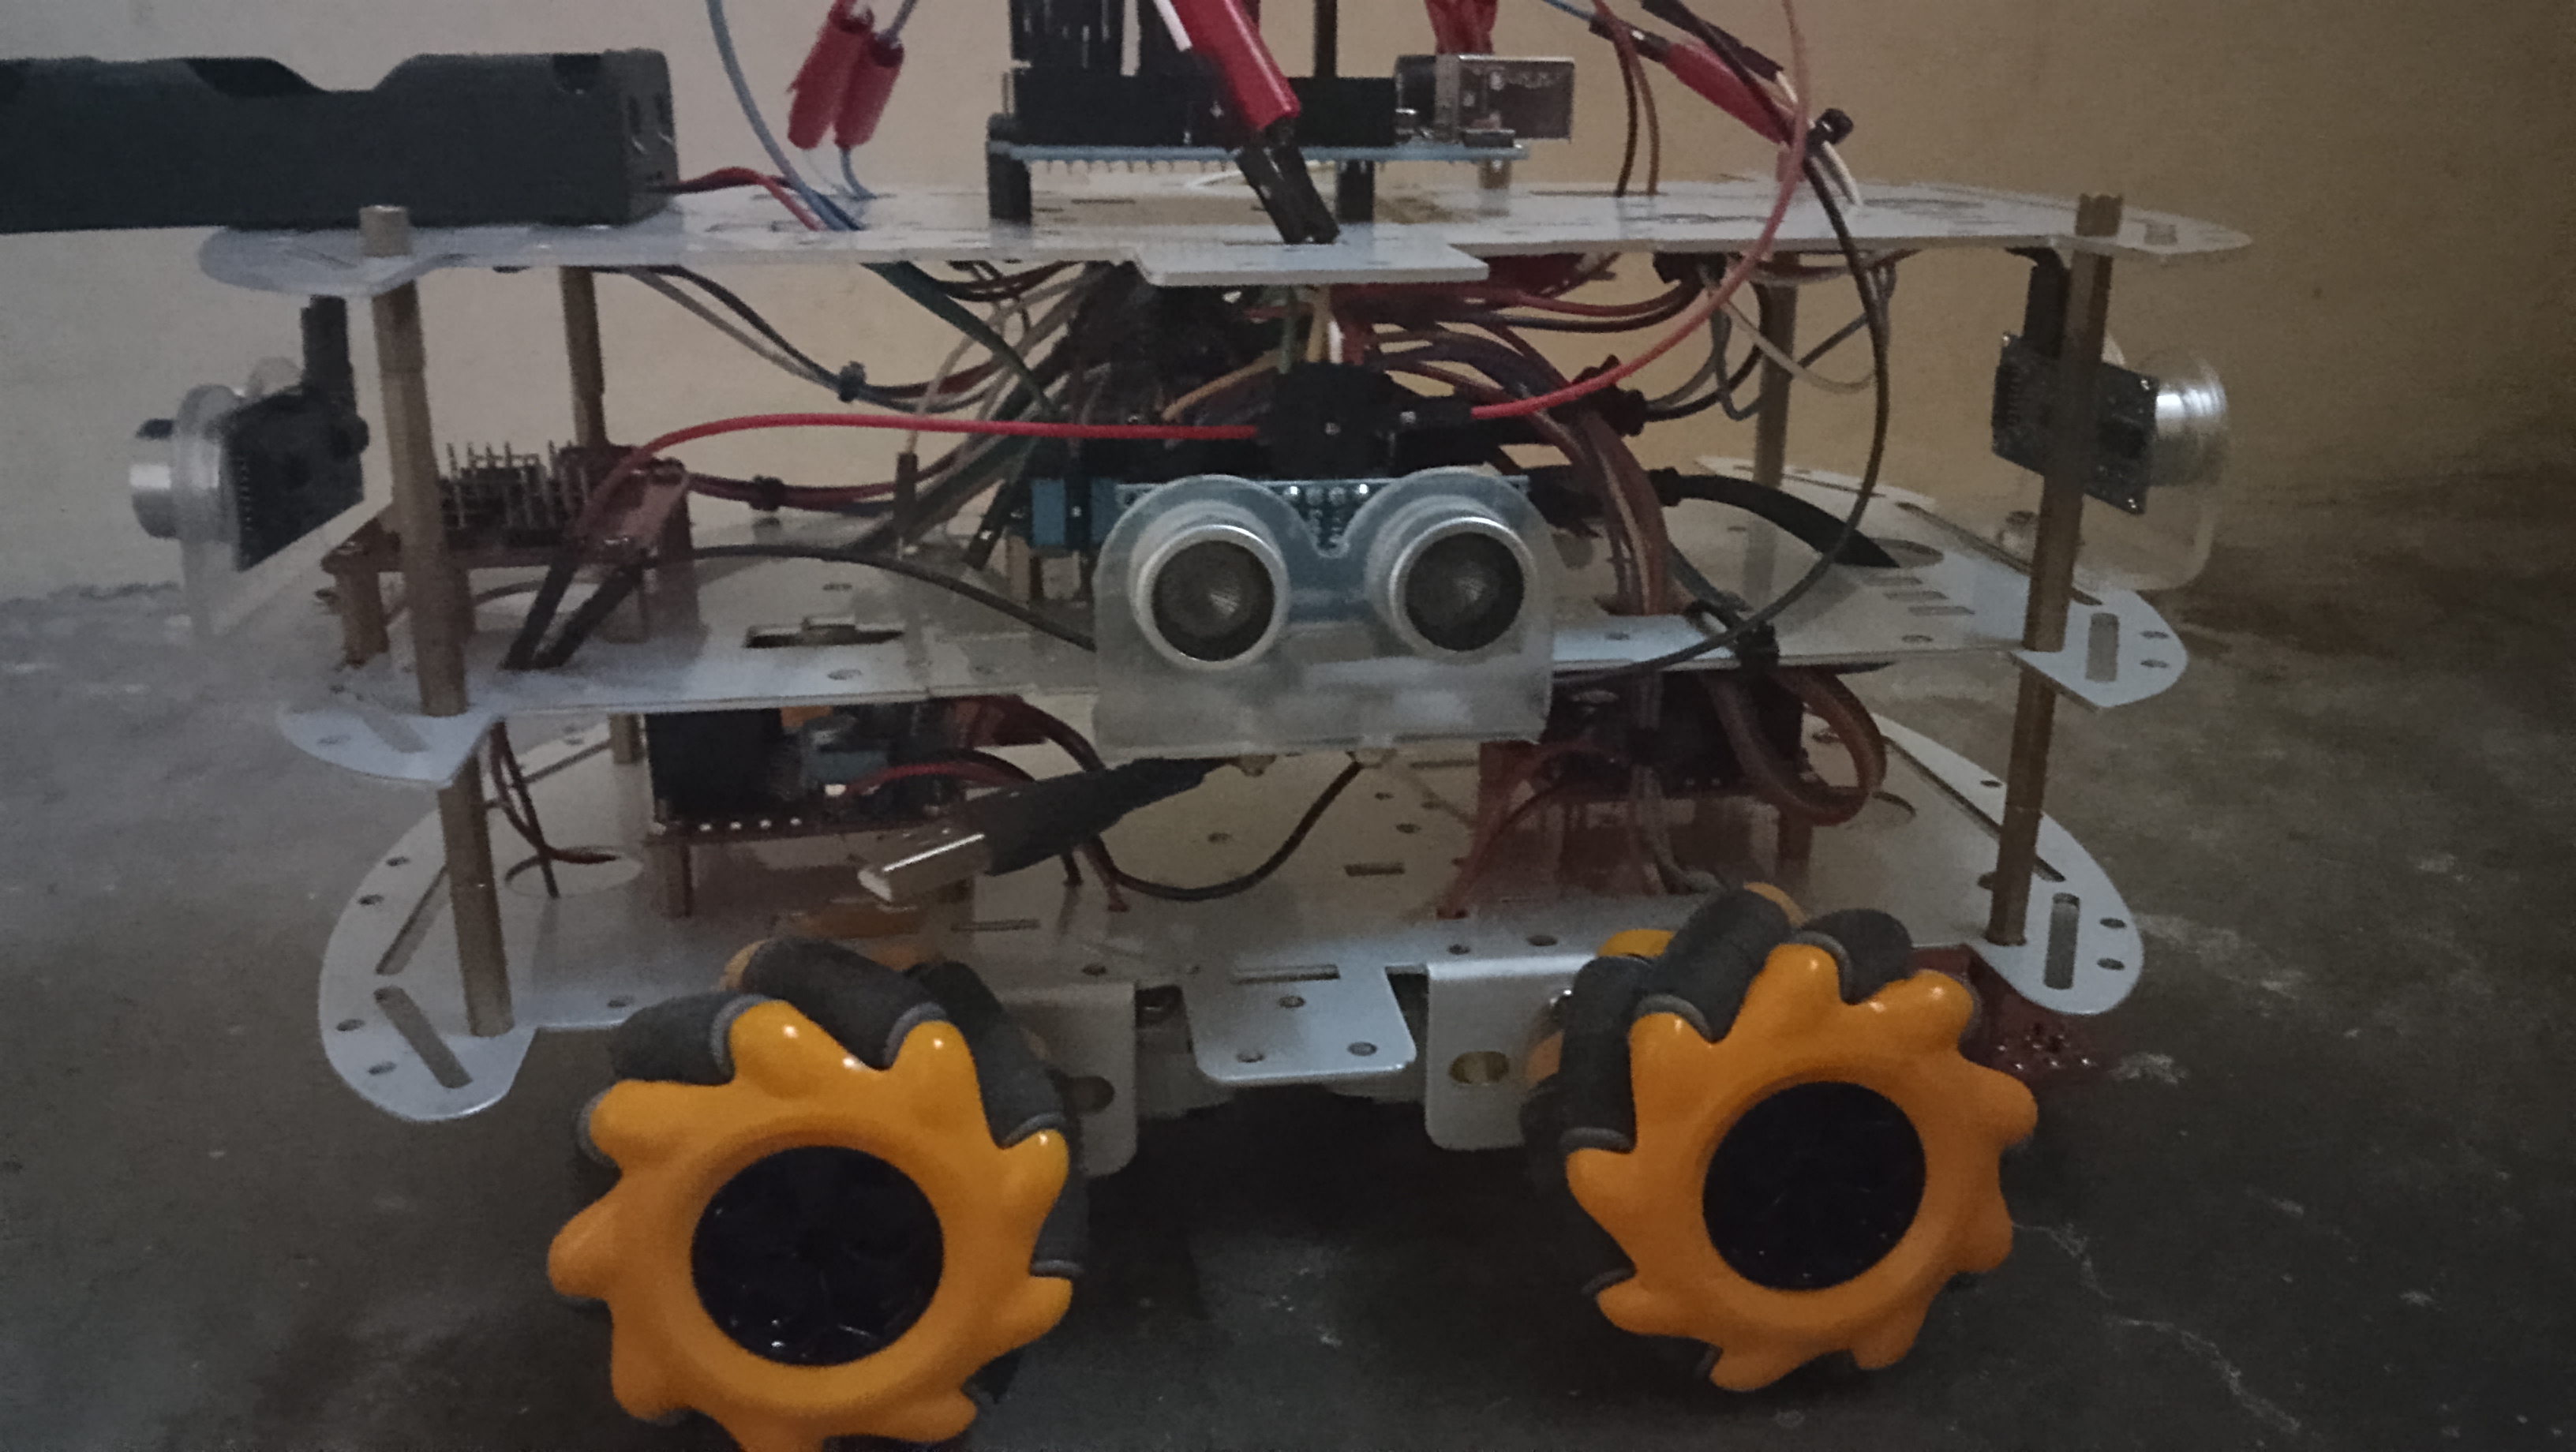
Mecanum wheels let her drive, strafe and turn in place.
The fleet's network
She runs the NORA access point and the fleet registry on port 5000, so no router is needed.
Four-way braking
HC-SR04 sensors front, back, left and right block any drive command that would hit something, with a buzzer warning.
MP3 player
Play, skip, repeat and volume from the web, the remote or the controller. A single clap starts the music.
Environment
Temperature and humidity (AHT10), ambient light, and a 3-channel line sensor.
UV light
A UV LED that can be off, on or blinking.
MIND mode
The LLM on her PC controller drives her: she looks, thinks out loud, says what she’s doing as the fleet’s boss, moves and remembers. N on the controller.
IDA’s mind too
H runs IDA’s mind over the IR link. IDA can’t report back, so her mind knows she’s blind and takes one short step at a time.
Remote and rumble
The remote’s 5 locks and frees her wheels, 6 / 7 slow her down and speed her up; a gamepad buzzes harder as she nears a wall in the way it drives her.
Hardware
What she's built from
- 01 ESP32 (ACEBOTT QA007 Max controller board)
- 02 Arduino UNO + VS1053 MP3 board
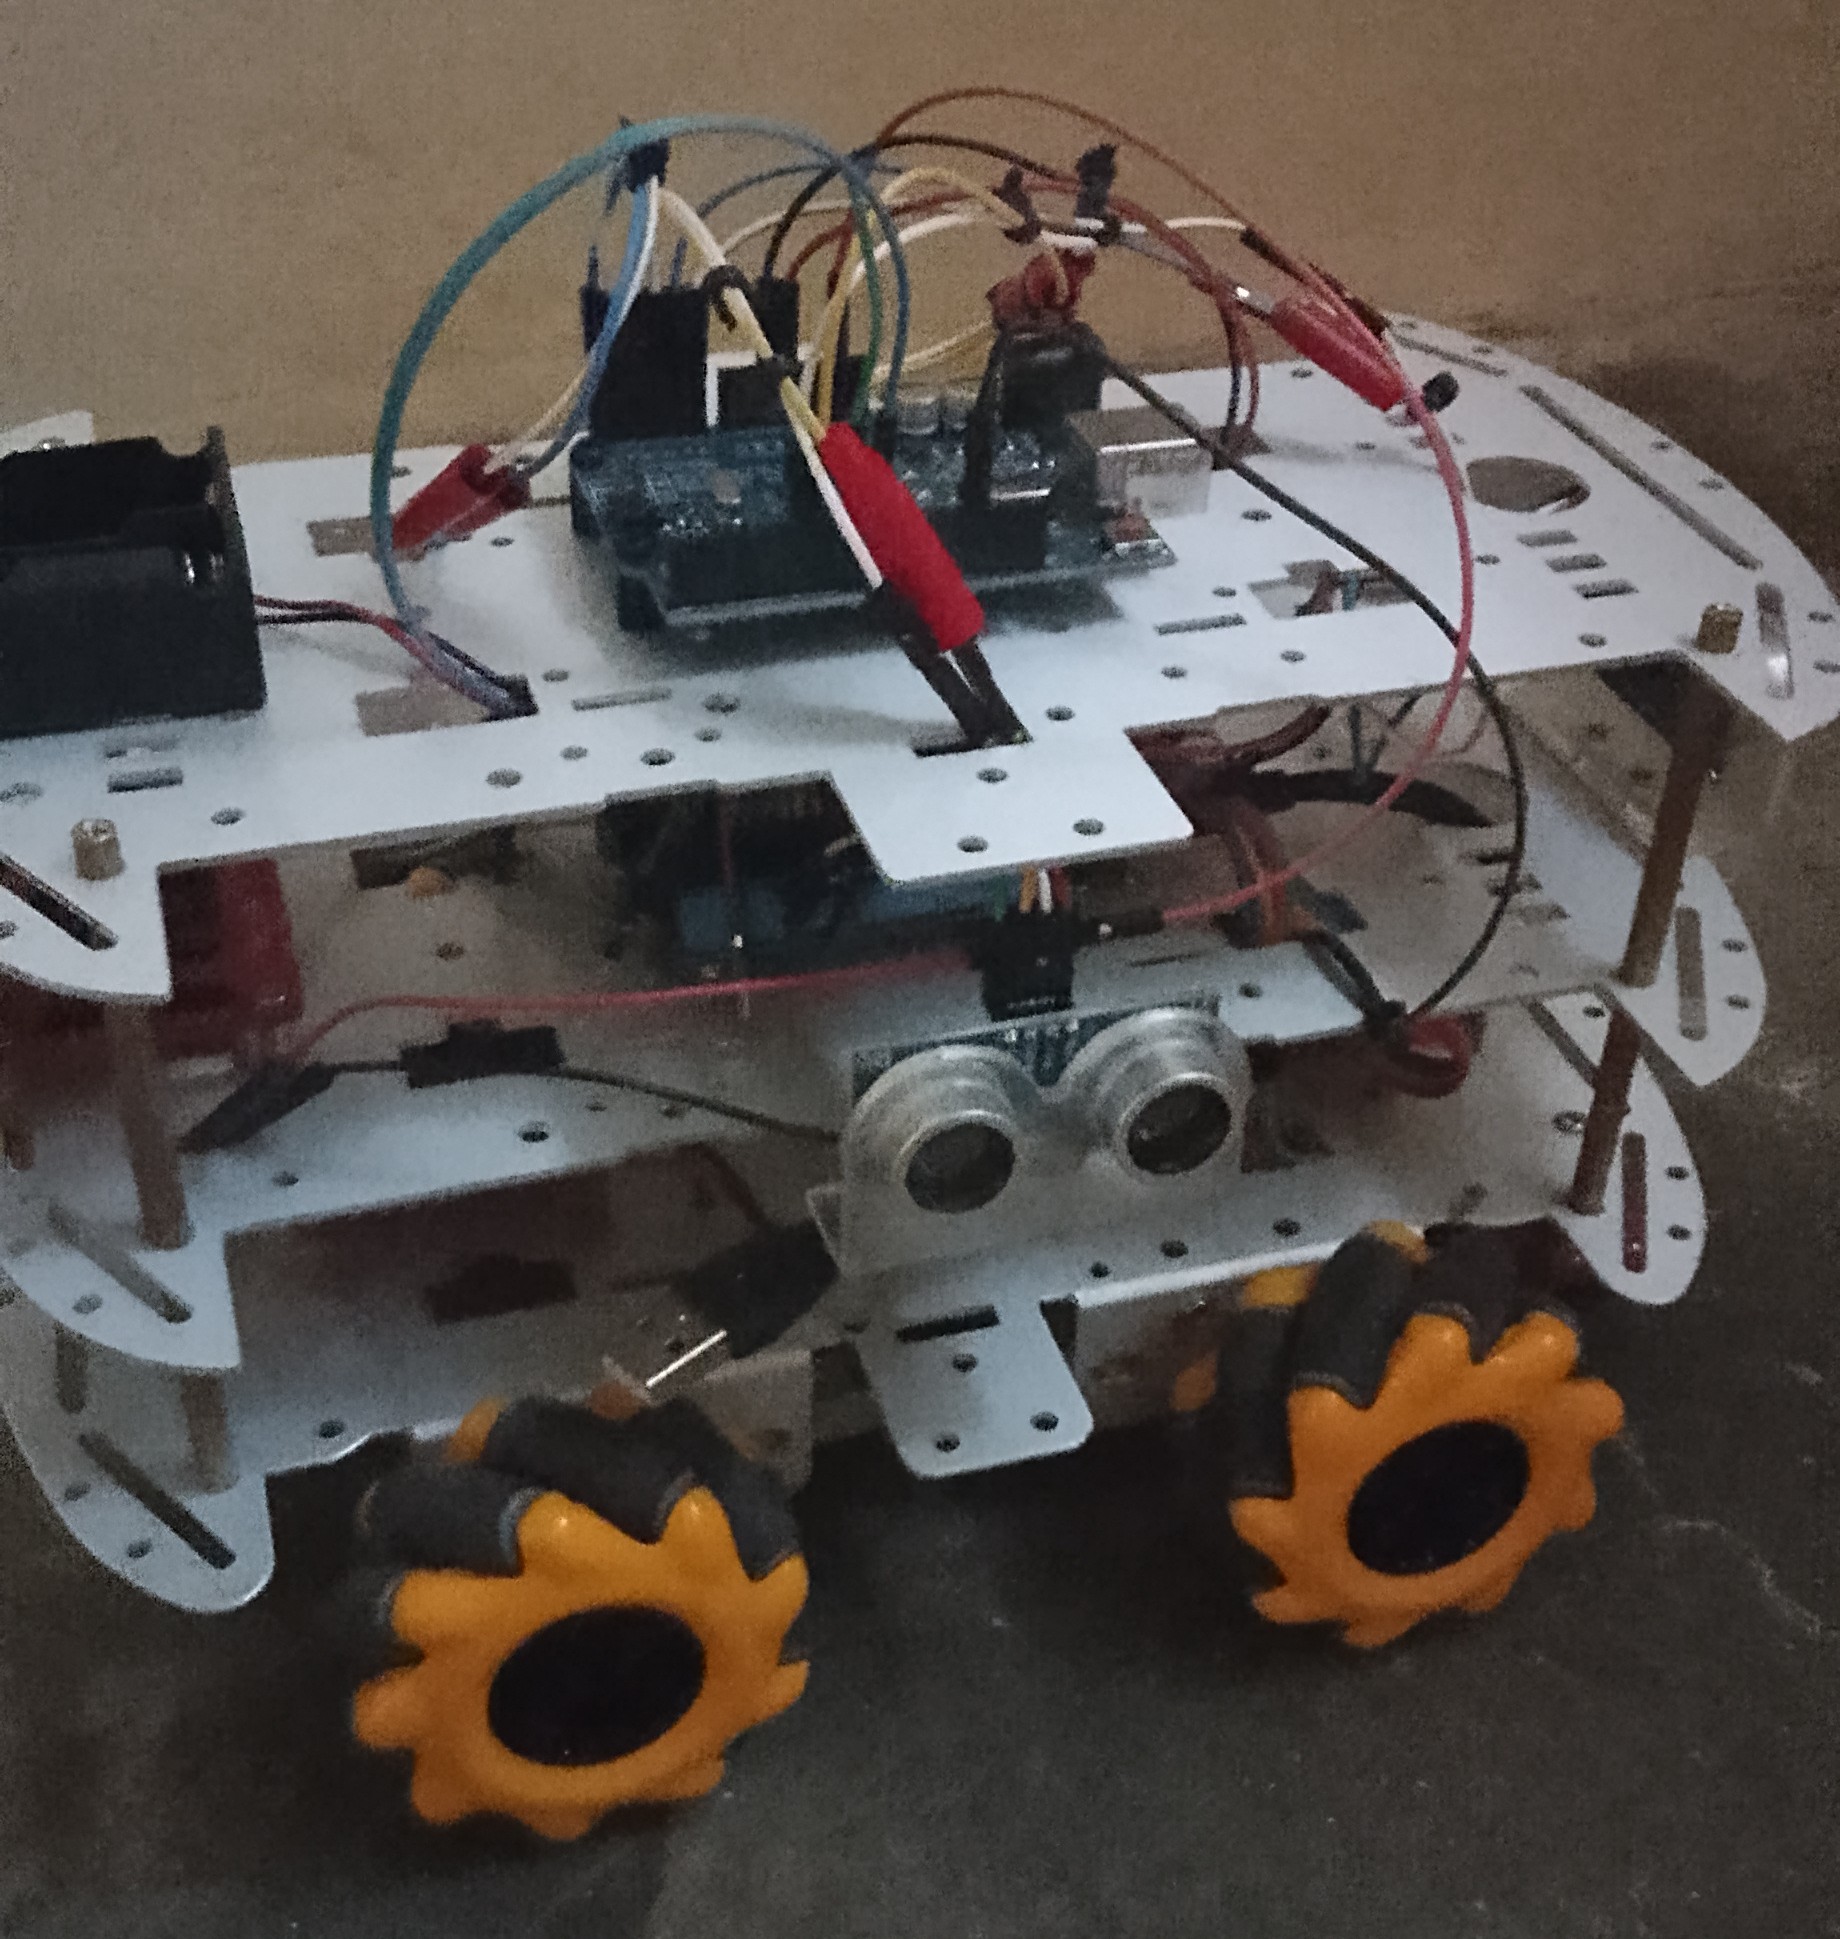
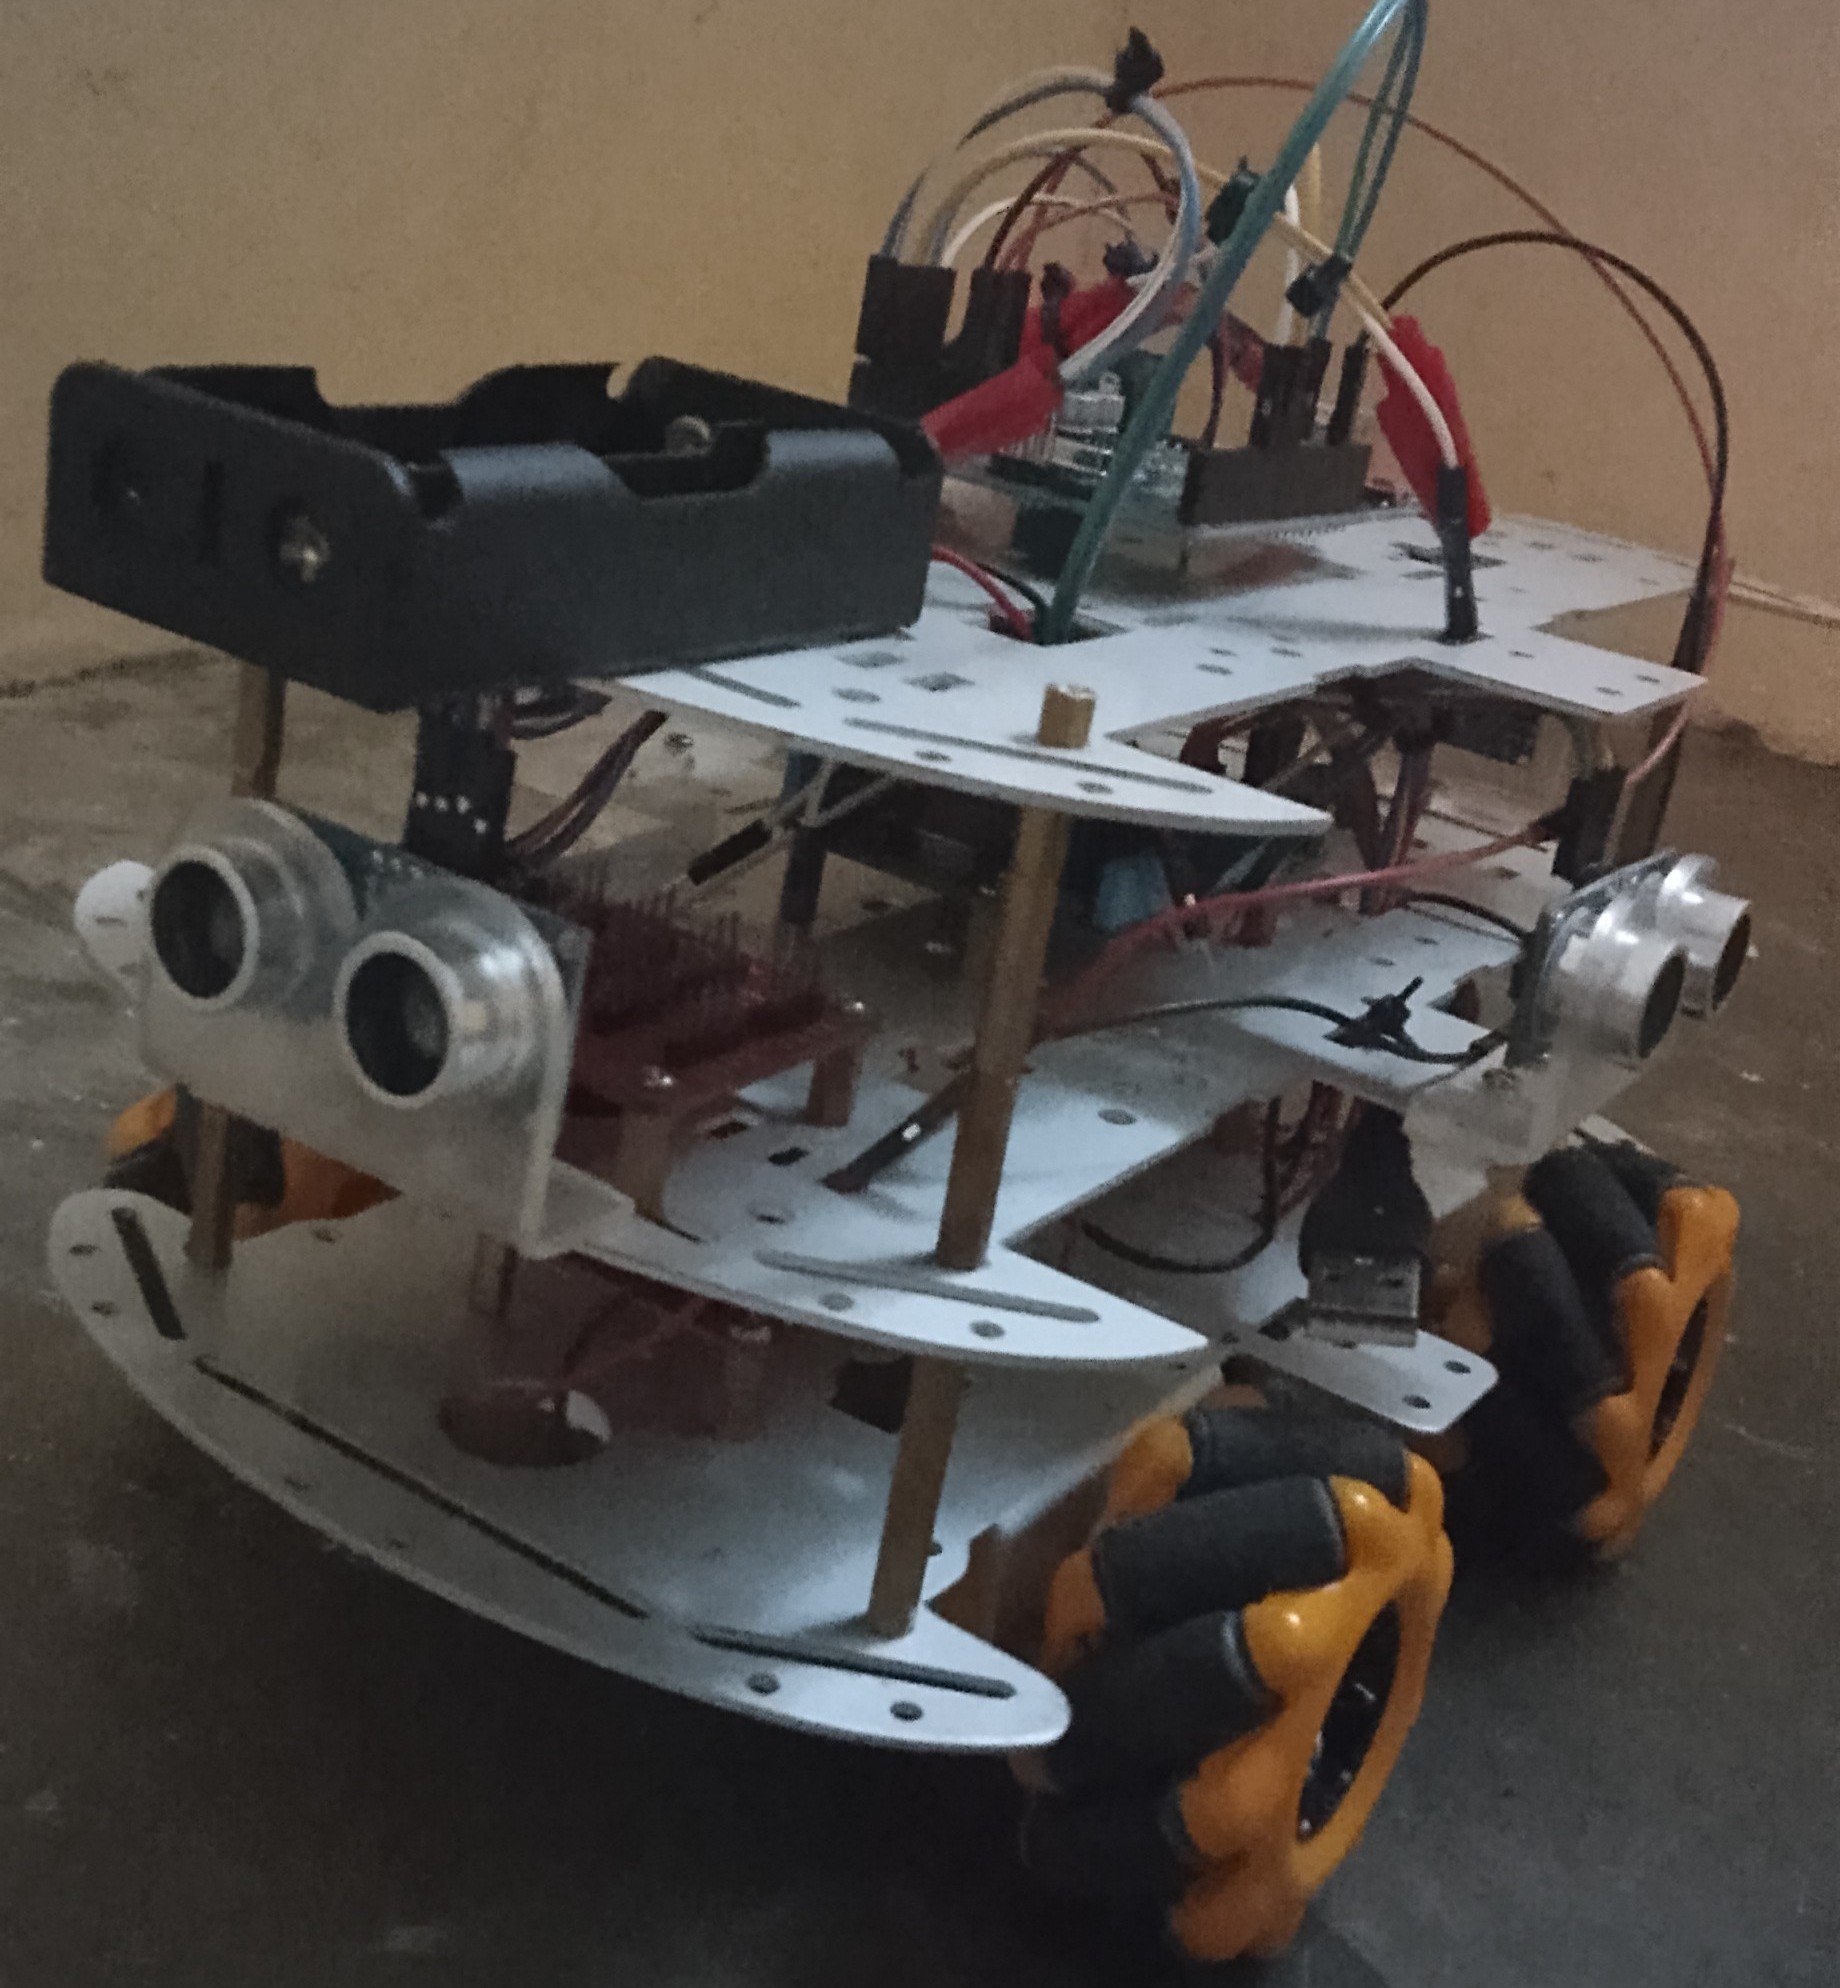
- 03 Mecanum robot chassis
- 04 2× L298N motor drivers
- 05 4× 5 V DC motors
- 06 2S 18650 battery pack
- 07 4× HC-SR04 ultrasonic sensors
- 08 3-channel line tracking sensor
- 09 AHT10 temperature / humidity
- 10 Photoresistor and sound sensor
- 11 Buzzer and UV LED
- 12 IR receiver and IR transmitter LED
- 13 TEA5767 FM radio module (planned)
ESP32 pinout
| Motors | PWM | Dir 1 | Dir 2 |
|---|---|---|---|
| M0 (front) | GPIO 5 | GPIO 16 | GPIO 17 |
| M1 (front) | GPIO 23 | GPIO 18 | GPIO 19 |
| M2 (rear) | GPIO 12 | GPIO 13 | GPIO 14 |
| M3 (rear) | GPIO 27 | GPIO 26 | GPIO 25 |
| Sensors & outputs | GPIO |
|---|---|
| Line follower L / M / R | 34 / 35 / 39 |
| UV LED | 4 |
| IR receiver (3.3 V) | 32 |
| IR transmitter | 33 |
| AHT10 SDA / SCL | 21 / 22 |
| TEA5767 FM radio (planned) | 21 / 22, 0x60 |
| UNO link | RX0 / TX0 |
UNO pinout
| Ultrasonic | Pin |
|---|---|
| TRIG (all four joined) | A4 |
| Front / right ECHO | A0 / A1 |
| Back / left ECHO | A2 / A3 |
| Other | Pin |
|---|---|
| Photoresistor | A5 |
| Sound sensor | D5 |
| Buzzer | D10 |
| ESP32 link | D0 / D1 |
The MP3 shield reserves D2–D4, D6–D9 and D11–D13. The boards talk over a 9600 baud UART on their hardware serial pins, so unplug the link before uploading to either board.
# UNO → ESP32: distances in cm, track, music state, light %, sound flag
F:23.4,L:10.1,B:45.0,R:8.3,MT:101,MS:1,LT:62,SND:0

# ESP32 → UNO
M:PLAY  M:NEXT  M:PREV  M:STOP  M:REPEAT  V:UP  V:DOWN  V:MUTE
BZ:SPD:<0-100>  BZ:MODE:<0-3>  BZ:UV:<0-2>  BZ:LOCK:<0|1>  BZ:DENIED
Common GND is non-negotiable. If the motors behave erratically or the sensors read 0, check the ground bridge between every module first.
Drive modes
Four ways to move
Web, controller, Bluetooth
D-pad control from the web page, the Python controller or Bluetooth serial.
Obstacle avoidance
Omnidirectional avoidance using all four ultrasonic sensors.
Line following
Follows a line with the 3-channel sensor.
Direct driving
Hold a D-pad direction to drive and let go to stop. Enter swaps left/right between strafing and turning.
The mode keys, music, volume and mute work in every mode. The D-pad and Enter only drive in IR remote mode, so they never fight the web driver or the autonomous logic. There's no key-up over IR, so a 250 ms gap with no repeat counts as “released”. The web page also has a motor lock (password 1234 by default). The button map is in ir_mapping.txt.
Voice
What NORA says
Her spoken lines, played from the MP3 shield's SD card: her modes, lock and UV (track200–track210), and her mind's phrase book (track211–track231), said from her own speaker when MIND mode drives her. Made with make_voice.bat (Windows text-to-speech + ffmpeg).
Connect
Flash and join her network
- Install the Arduino IDE with the ESP32 boards and the CH340 driver.
- ESP32 libraries:
IRremote4.x andAdafruit AHTX0. UNO libraries:SFEMP3ShieldandSdFatfrom the SparkFun MP3 Player Shield library. - For the ESP32, pick a bigger app partition under Tools → Partition Scheme: Huge APP (3MB No OTA/1MB SPIFFS) or Minimal SPIFFS (1.9MB APP with OTA).
- Flash
scripts/esp32andscripts/arduinowith the serial link unplugged, reconnect it, power her on and join her WiFi.
| Setting | Value |
|---|---|
| WiFi SSID | NORA |
| Password | 12345678 |
| Control page | http://192.168.4.1:5002 |
| Fleet registry | http://192.168.4.1:5000 |
| Bluetooth | Device NORA |
$ pip install -r requirements.txt
$ python scripts/controller.py              # WiFi
$ python scripts/controller.py --bt COM7    # Bluetooth serial
Fleet IR link
NORA drives IDA, MILA, WHIP and KIDA-01 through her IR transmitter on GPIO 33: Samsung-format IR, one address per robot, the same commands 0x48–0x4F for all. Pick the robot with the panel's tabs (or Tab in the Python controller); its avatar, name and colour follow. Drive commands repeat every 150 ms while held; each robot stops by itself if the link goes quiet.
| Robot | Address | Receiver |
|---|---|---|
| IDA | 0x0DA1 | IDA.ino |
| MILA | 0x0DA2 | MILA.ino |
| WHIP | 0x0DA3 | esp32.ino |
| KIDA-01 | 0x0DA4 | arduino01 sketch |
| NIKA | 0x0DA5 | NIKA.ino |
| From | Drive | Stop | Obstacle | Manual | Speed |
|---|---|---|---|---|---|
| Web page | I K J L | button | button | button | button |
| Python controller | I K J L | release | O | P | Y |
| HTTP | /link?r=mila&c=fw | stop | auto | manual | speed |
| Bluetooth | T + robot I M W K + F B L R | …S | …O | …W | …X |
Talking with the fleet
Every 30–90 s, when she isn’t driving anyone, NORA says something to IDA in Brainfuck: every phrase is a program that prints its words (hello is ++++++++[>+++++++++++++<-]>.+. → hi), beeped one tone per symbol. Once she’s finished she sends it over the link and IDA beeps her reply. RIFT has her chat with the other robots over WiFi too. A silent “I am here” beacon goes round the fleet in between, and IDA greets NORA when she comes back after a minute away. GET /talk returns the conversation log as JSON; /talk?r=ida&p=hello (or SAY HI on the panel) says one now. Phrases: 0x40 hello, 0x41 how are you, 0x42 happy, 0x43 curious, 0x44 sleepy, 0x45 let’s play, 0x46 bye, 0x47 “I am here” beacon (silent).
Connect through RIFT at the same address. Board docs: ACEBOTT ESP32 Max V1.0.
Who's nearby
ESP-NOW + Bluetooth LE: the robots sense each other
Every robot sends a small "I'm here" beacon twice a second. The signal strength says roughly how close each one is, and how it changes says whether it's coming closer, steady or leaving. Coarse, for "who's around": the ultrasonic and ToF sensors still do the precise avoiding.
Very close to far
Above −45 dBm very close, −60 near, −75 medium, below that far.
In Brainfuck
Over ESP-NOW each beacon carries a program that prints park, go, wait or hand; the receiver runs it. RIFT decodes them too.
Who makes way
A parked robot isn't the one moving; a yielding one is making way; a human-driven one gets space; otherwise the alphabet decides, and everyone makes way for MILA.
NORA hears the others over ESP-NOW (WHIP, MILA) and Bluetooth LE (WHIP and the Pi robots KIDA-00 / KIDA-01). In Auto mode she slows down while a robot is near and gives way when one with right of way is very close; in Line mode she waits on the line. GET /near shows her list.
Screens
The controllers
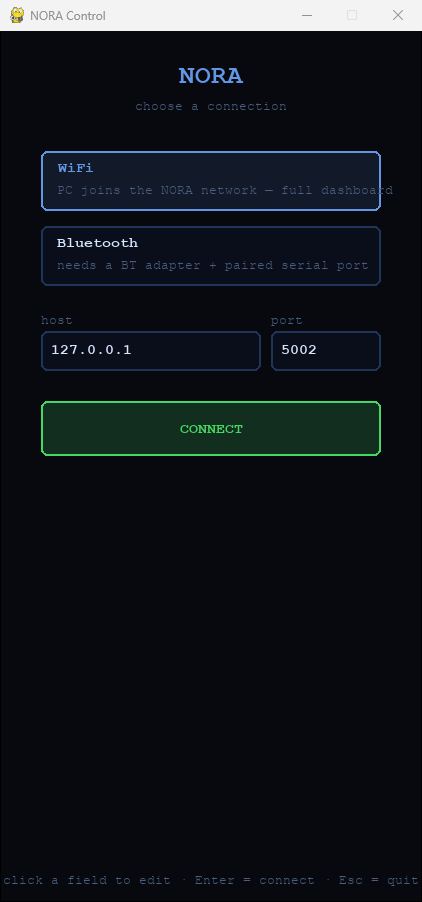
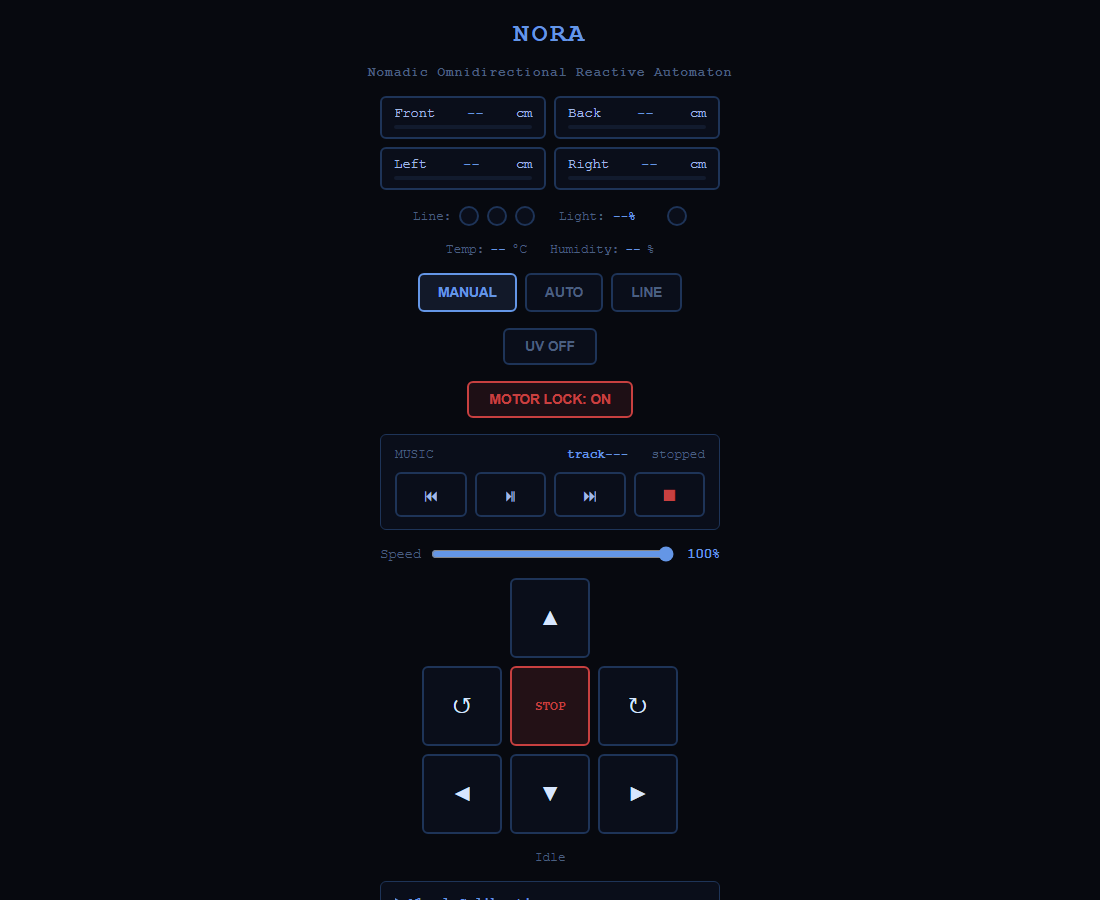
Captured without a robot connected, so live values show their offline state.
Windows app
A native window on NORA's page
It opens NORA's own hosted page in a window, so it always looks the same as the page. It remembers the address, and FIND looks on the fleet list of the network you're on. If NORA doesn't answer, it says so and lets you change the address.
STAY CLOSE: press STAY on RITA and she keeps near her, in your hand, stopping about a metre away. It's only been tested in simulation so far.
Her ESP32 page now looks like her Python controller, with a view of her from above.