Overview
A scout that sees, drives and decides
An Android app
Hold the stick to drive, let go to stop, with her modes, photos and music as buttons.
Hello, dance, Brainfuck
She shakes her camera and dances on the spot, and says the fleet’s Brainfuck phrases on her speaker in RIFT’s conversations.
Multi-protocol
Drive her from the web interface, over VNC, from the desktop remote controller or with a wireless keyboard.
Live surveillance
HD video streaming with on-demand photo and video capture.
Biometric inference
Edge vision processing for real-time gender and age detection, right on the Pi.
Reactive behaviours
Ultrasonic obstacle avoidance and high-contrast line following.
Visual feedback
Customisable RGB lighting for status signals and lighting up her surroundings.
Desktop controller
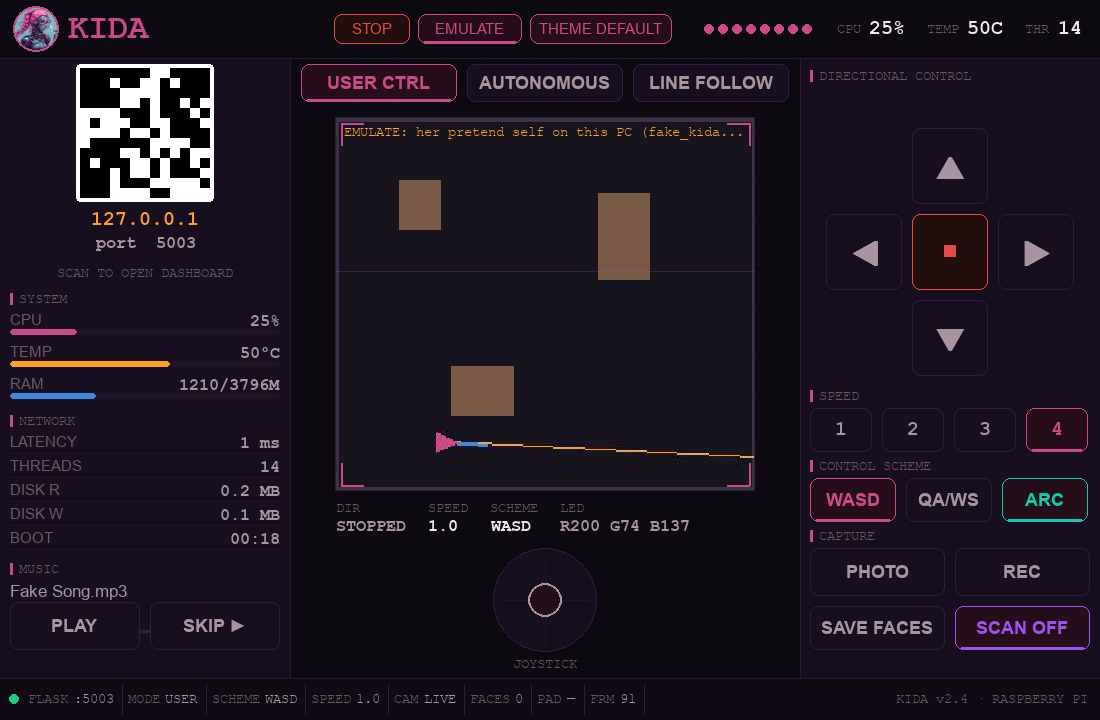
The same HUD as the robot, running on another PC, with keyboard, mouse and gamepad support.
No driving into walls
Whatever drives her — keys, tank, gamepad, web, line following — she won’t go forward into anything within 15 cm. Turning and reversing still work.
Hardware
What she's built from
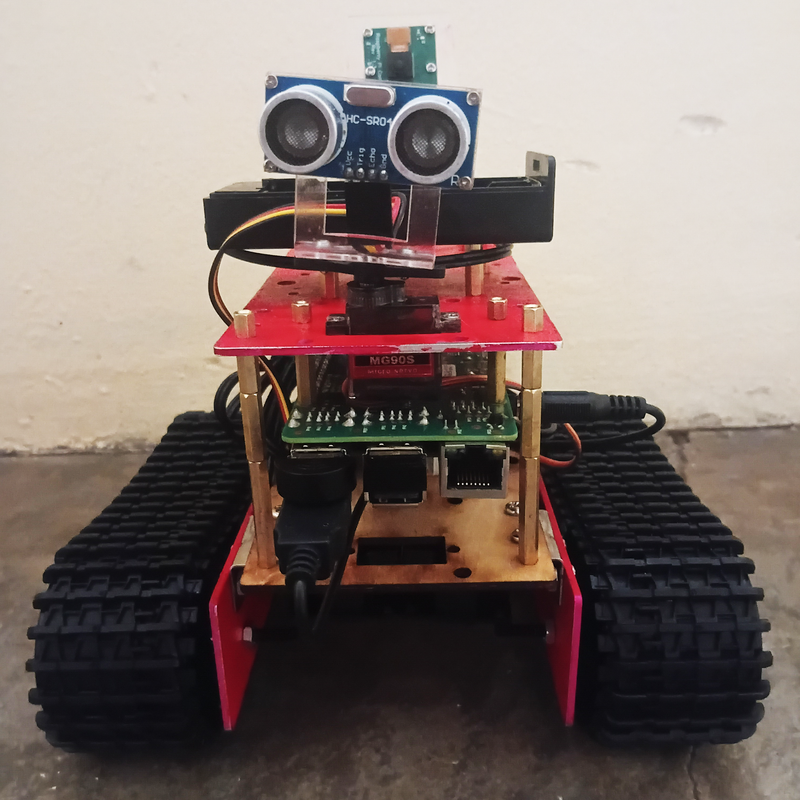
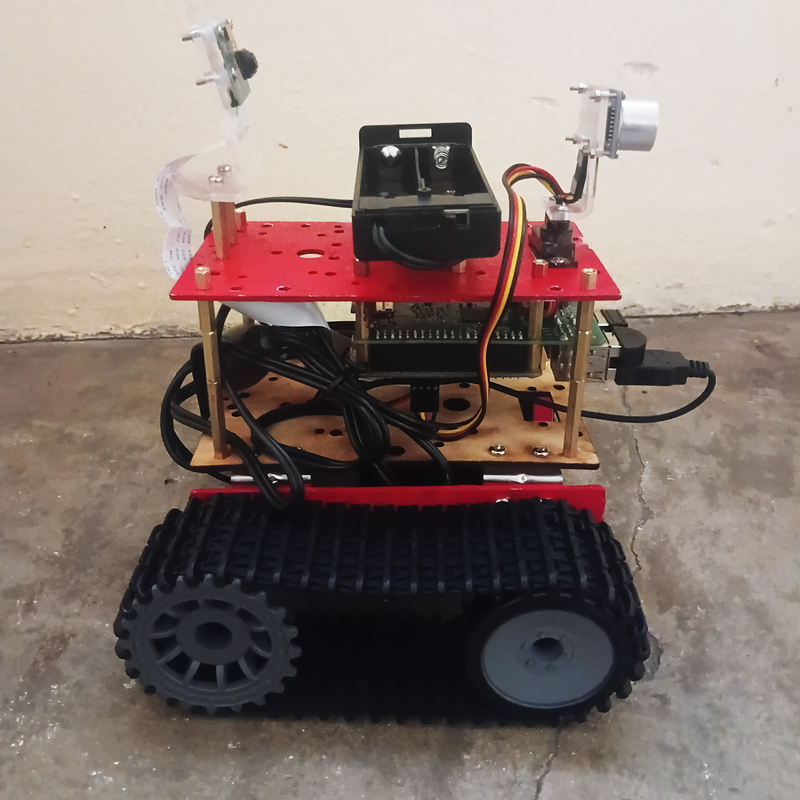
- 01 Raspberry Pi 3B
- 02 Freenove Tank Robot HAT v2
- 03 Robot tank chassis
- 04 2× 5 V DC motors
- 05 Raspberry Pi camera
- 06 HC-SR04 ultrasonic sensor
- 07 3-channel line tracking sensor
- 08 2S 18650 battery pack
- 09 PC, Android or iPhone + wireless keyboard
Pinout
KIDA uses the v2 HAT from the Freenove Tank Robot. These are its GPIO assignments.
| Sensors & outputs | GPIO |
|---|---|
| Ultrasonic TRIG | 27 |
| Ultrasonic ECHO | 22 |
| Servo 0 / 1 / 2 | 12 / 13 / 19 |
| LED pixel | 10 |
| IR01 / IR02 / IR03 | 16 / 26 / 21 |
| Motors | GPIO | |
|---|---|---|
| Left IN1 / IN2 | 23 / 24 | M1+ / M1− |
| Right IN1 / IN2 | 6 / 5 | M2+ / M2− |
Music
What KIDA plays
The tracks on KIDA's music player, straight from audio/music/.
Quick start
From SD card to driving
Install Raspberry Pi OS, clone the repo onto the Pi, then set up the environment:
$ python3 -m venv venv
$ source venv/bin/activate
$ pip install --upgrade pip
$ pip install -r requirements.txt
Run her with Python, or with the shell scripts (give them permission once):
$ python run.py

$ chmod +x make_executables.sh && ./make_executables.sh
$ ./run.sh                     # main environment
$ ./linefollower.sh            # one behaviour on its own
$ ./obstacle_avoidance.sh
Remote controller
The same window as the robot's HUD, running on another PC. The first run creates controller/venv with just pygame and requests.
$ ./run.sh 192.168.1.50                       # Linux / macOS (from controller/)
> run.bat 192.168.1.50                        # Windows
$ python main.py http://192.168.1.50:5003 --fullscreen
Controls
Two ways to drive
Standard WASD vectoring
W/S forward and back, A/D rotate. Smooth, cinematic driving.
Tank-style tracks
Q/A drive the left bank, W/S the right. Best for heavy terrain and precise pivots.
Keys
| Key | Action |
|---|---|
| TAB | Cycle modes |
| U / O / L | User control / autonomous / line follower mode |
| X | Speed control |
| C / V | Take a photo / record video |
| M / Space | Play music / stop music |
Gamepad
Xbox, PlayStation, Switch Pro and most others work the same on the robot, the remote controller and the web dashboard. Plug one in any time.
| Button | Action |
|---|---|
| Left stick | Drive (analog). Both sticks drive the tracks in the tank scheme |
| D-pad | Drive like WASD |
| A / B | Cycle speed / stop |
| X / Y | Photo / arc turns on-off |
| LB / RB | Previous / next mode |
| Back / Start | Save faces / play-pause music |
Safety: she stops any remote drive she hasn't heard about for 0.8 s, so a dropped connection or a closed window never leaves her driving.
Connectivity
Join the fleet
| Setting | Value |
|---|---|
| WiFi SSID | NORA |
| Password | 12345678 |
| RIFT / remote controller port | 5003 |
Open her address on port 5003 in any browser on the same network to get the HTML remote controller, or connect through RIFT.
Who's nearby
ESP-NOW + Bluetooth LE: the robots sense each other
Every robot sends a small "I'm here" beacon twice a second. The signal strength says roughly how close each one is, and how it changes says whether it's coming closer, steady or leaving. Coarse, for "who's around": the ultrasonic and ToF sensors still do the precise avoiding.
Very close to far
Above −45 dBm very close, −60 near, −75 medium, below that far.
In Brainfuck
Over ESP-NOW each beacon carries a program that prints park, go, wait or hand; the receiver runs it. RIFT decodes them too.
Who makes way
A parked robot isn't the one moving; a yielding one is making way; a human-driven one gets space; otherwise the alphabet decides, and everyone makes way for MILA.
A Pi can't speak ESP-NOW, so KIDA-00 uses the Pi's own Bluetooth LE to hear NORA, WHIP, KIDA-01 and RIFT and be heard. In autonomous mode she slows down near other robots and gives way when one with right of way is close; in line mode she waits. GET /near shows her list.
Screens
The controllers
Captured without a robot connected, so live values show their offline state.
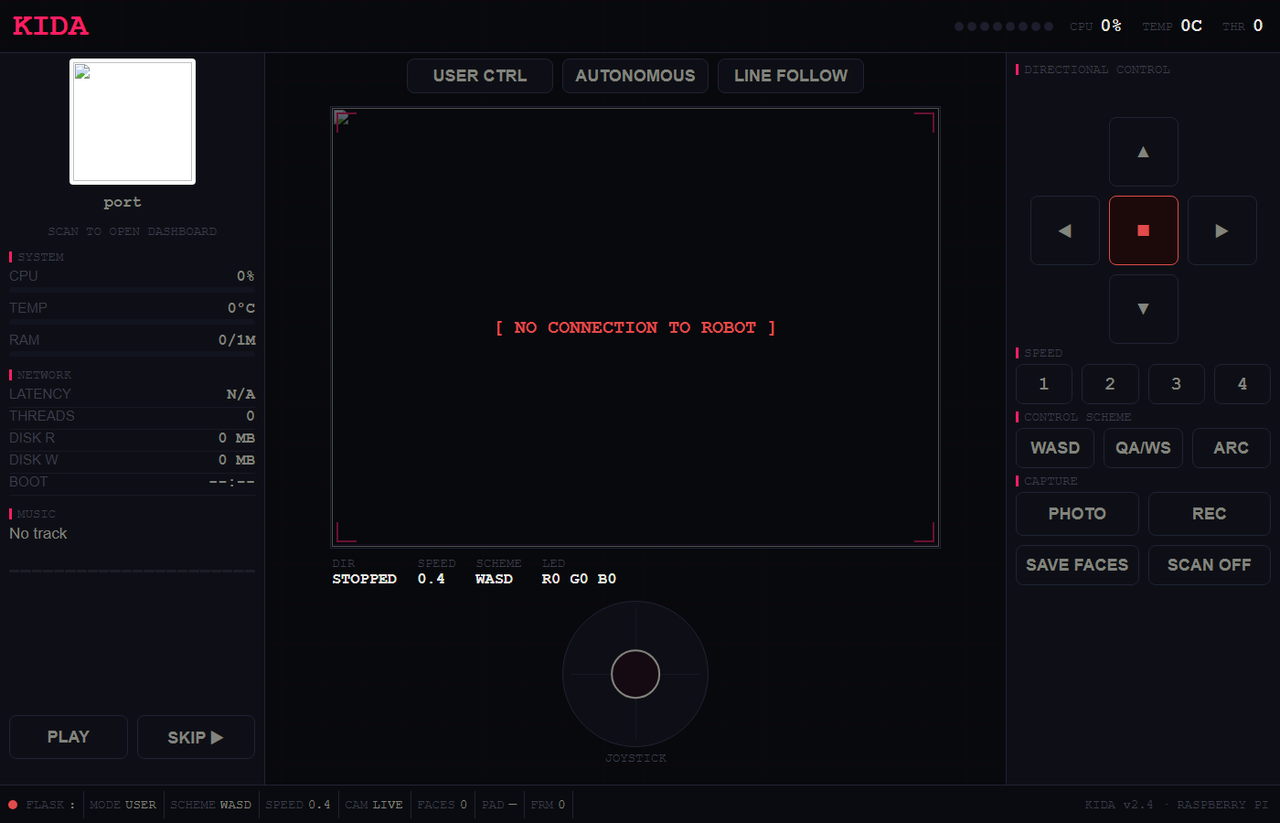
Windows app
A native window on KIDA-00's page
It opens KIDA-00's own hosted page in a window, so it always looks the same as the page. It remembers the address, and FIND looks on the fleet list of the network you're on. If KIDA-00 doesn't answer, it says so and lets you change the address.
Her Android app now shows her camera. If there's no picture, her page and PC controller say why.